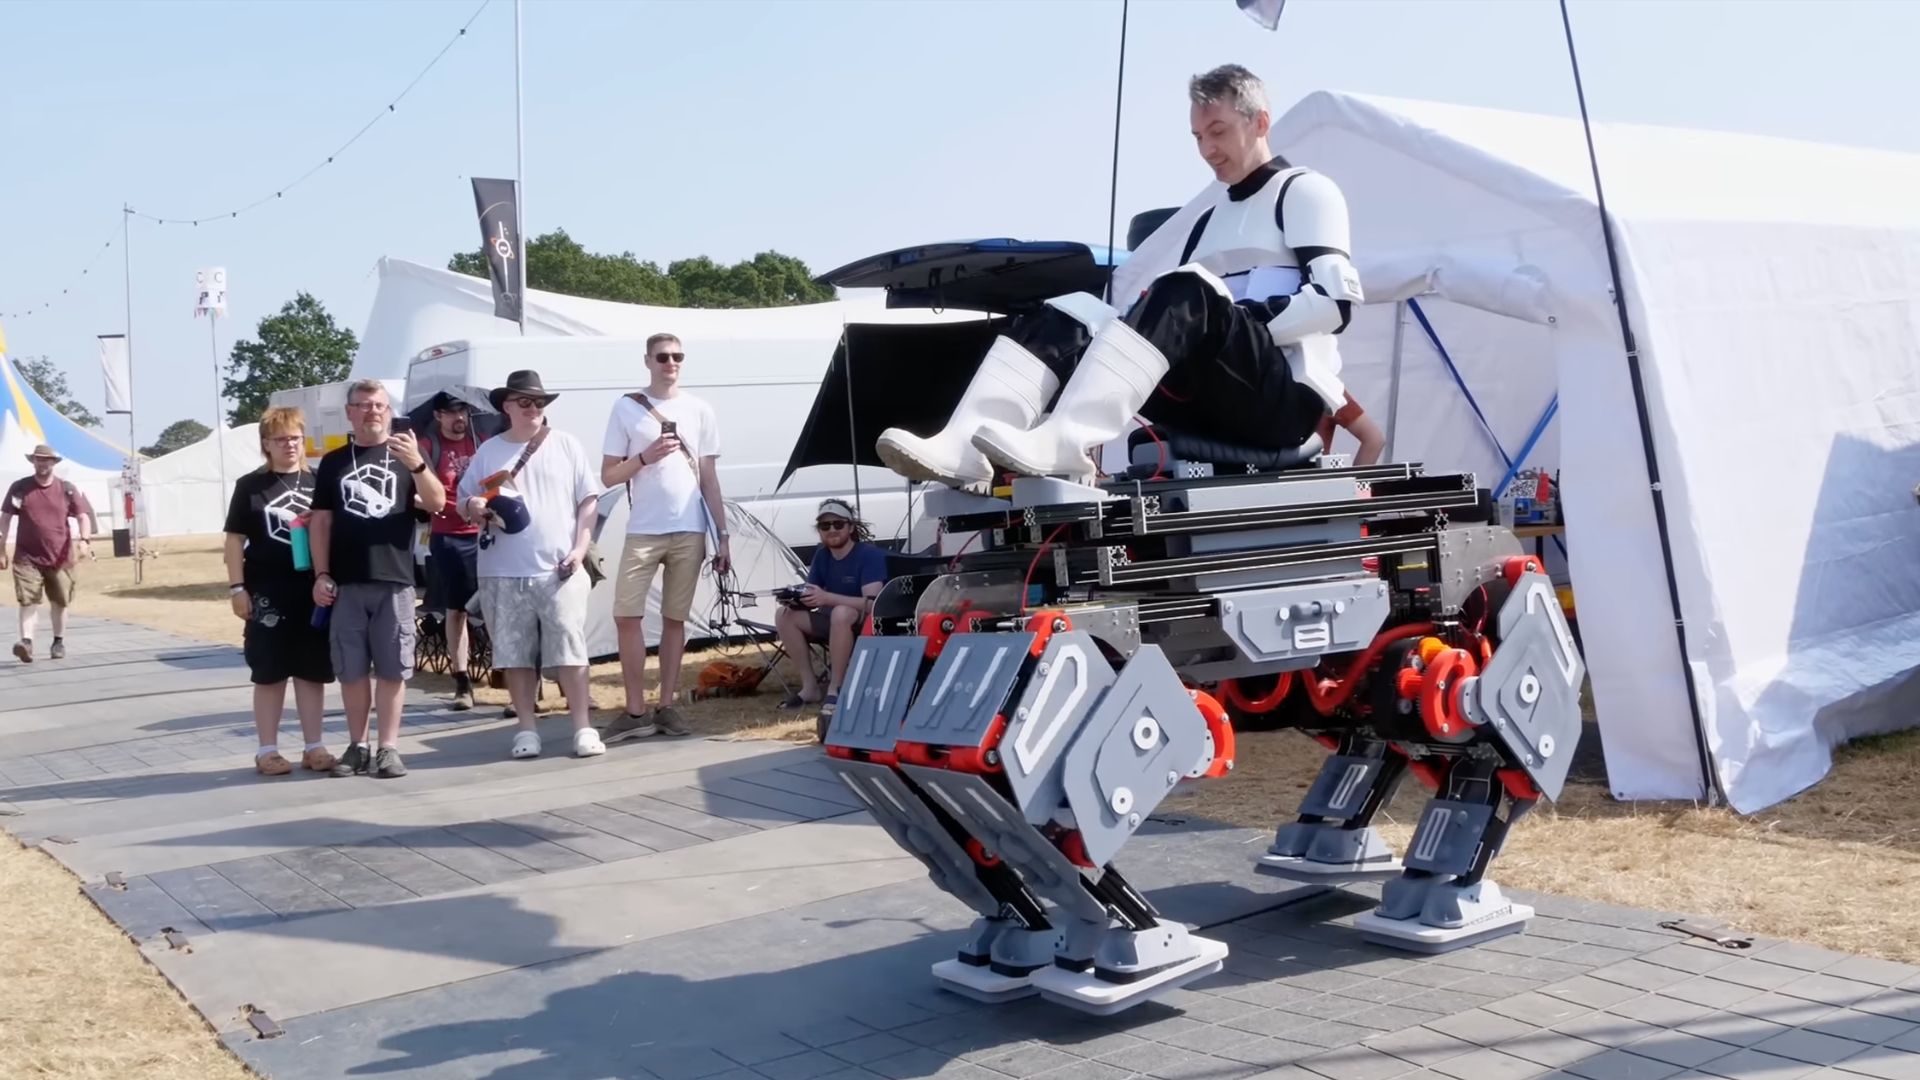
In the world of robotics, innovation often comes from unexpected places, and this story is a perfect example. James Bruton, a YouTuber and robotics enthusiast, has developed an intriguing quadruped robot with a unique ability: it can carry a human rider. However, as Bruton discovered, designing a stable walking machine is a complex challenge, especially when it comes to navigating uneven terrain.
The Mid-Walker's Journey
The Mid-Walker, as Bruton has named his creation, showcases the power of open-source projects. By sharing his work on GitHub through XRobots, Bruton has not only advanced the field of robotics but also inspired others to explore and improve upon his design.
One of the key features of the Mid-Walker is its diagonal leg arrangement, which ensures stability on flat surfaces. The legs move in pairs, keeping two feet on the ground at all times. This design choice, while effective on level ground, becomes a liability when faced with dips and hollows.
The Challenge of Uneven Terrain
When a foot lands in a dip, it can shift the machine's weight, causing it to tip. To counter this, Bruton implemented a sliding section beneath the seat, allowing the rider's weight to shift and maintain balance. However, even this innovative solution fell short when faced with soft grass and uneven terrain.
Inspiration from Bean Bags
In a stroke of creativity, Bruton turned to an everyday object for inspiration: the humble bean bag. He sought to replicate the way a bean bag's filling shifts and packs beneath a person's weight, providing stability. This led to the development of new feet for the Mid-Walker, filled with dried beans and 3D-printed dice.
Field Testing and Limitations
Field testing at Electromagnetic Field Camp revealed both the strengths and weaknesses of the design. While the Mid-Walker performed admirably on level grass and trails, it struggled when a foot landed in a hollow. The beans shifted, causing the sole to curl and the machine to roll over. Bruton experimented with different filling levels and even added zip ties, but the issue persisted.
Towards a Durable Solution
The experiments highlighted the need for a filling that could conform to the ground yet remain stable under heavy loads. Bruton considered using BB pellets to improve the locking effect and even explored vacuum systems. However, he ultimately favored a simpler approach: passive two-way pivot ankles that can self-level and lock in place. This design, he believes, will provide the stability needed to navigate uneven terrain.
The Future of Walking Machines
Bruton's work with the Mid-Walker showcases the iterative nature of robotics design. Each challenge and limitation presents an opportunity for improvement. As he continues to refine his creation, we can expect to see advancements in walking machine technology, bringing us closer to a future where these machines can navigate the world with ease.
In my opinion, stories like these remind us of the importance of creativity and collaboration in scientific advancement. By sharing his journey and inviting others to contribute, Bruton has not only pushed the boundaries of robotics but also inspired a community of enthusiasts to explore and innovate.
What makes this particularly fascinating is the way everyday objects can inspire groundbreaking solutions. It's a reminder that innovation often comes from unexpected places, and that's what makes science and technology so exciting!